Key Clinical Takeaways
- Robotic stereoscopic vision tracks follicular orientation and subcutaneous angles 60 times per second.
- Follicular transection is reduced to under 1.5% compared to higher fatigue-driven rates in manual extraction.
- Algorithmic donor mapping protects the safe donor area against over-harvesting and moth-eaten donor thinning.
The Computational Power of Stereoscopic 3D Vision
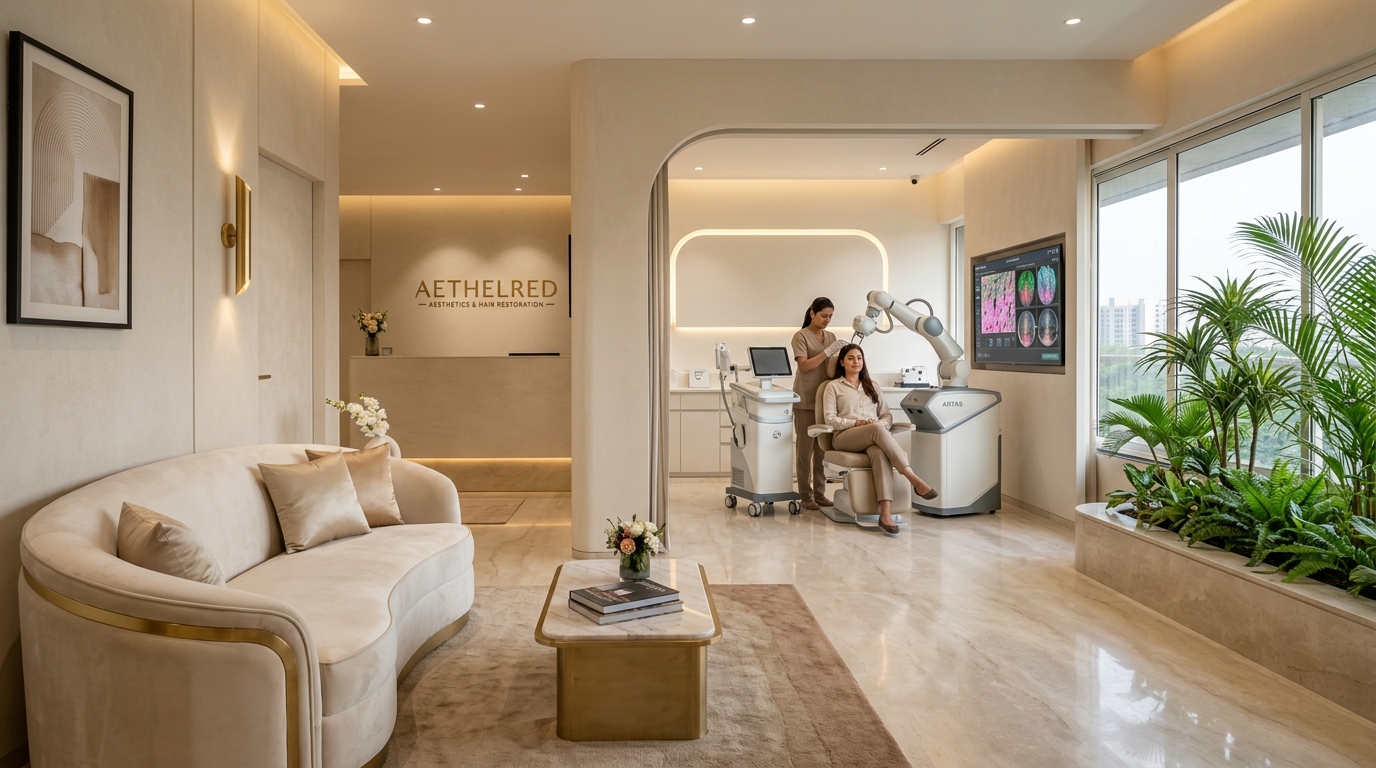
Manual extraction relies entirely on the surgeon's naked eye or static loupes. However, curly or angled subcutaneous hair shafts can bend beneath the skin surface. The ARTAS 9X system scans each follicular unit at 60 frames per second, calculating depth, exit angle, and hair count before making a micron-calibrated punch.
- Identifies 1, 2, 3, and 4-hair follicular clusters with 99% accuracy.
- Selective harvesting preserves surrounding donor density effortlessly.
- Zero human hand tremor or physical fatigue during large 3,500+ graft sessions.
Donor Protection: Preventing Over-Harvesting
One of the greatest tragedies in modern hair restoration is over-harvested donor areas that leave visible linear scars or patchy bald spots. The robotic system maintains strict spacing parameters, leaving 2 to 3 intact follicles between every extracted unit for invisible donor recovery.
"No two scalps or skin barriers share identical biological parameters. True clinical excellence lies not in aggressive standard packages, but in microscopic diagnosis and mathematically calibrated preservation tailored to Indian skin."
Dr. Navnit Haror
MBBS, MD - Dermatology (Gold Medalist), ISHRS • Founder & Chief Dermatologist, Hair Restoration Specialist
Practicing in Ahmedabad at Dr. Haror's Wellness, dedicated to high-precision robotic hairline restoration, microscopic follicular viability, and evidence-based clinical dermatology.
Consult with Navnit